 igaue()sensor.mech.chuo-u.ac.jp
 0000-0002-0182-834X
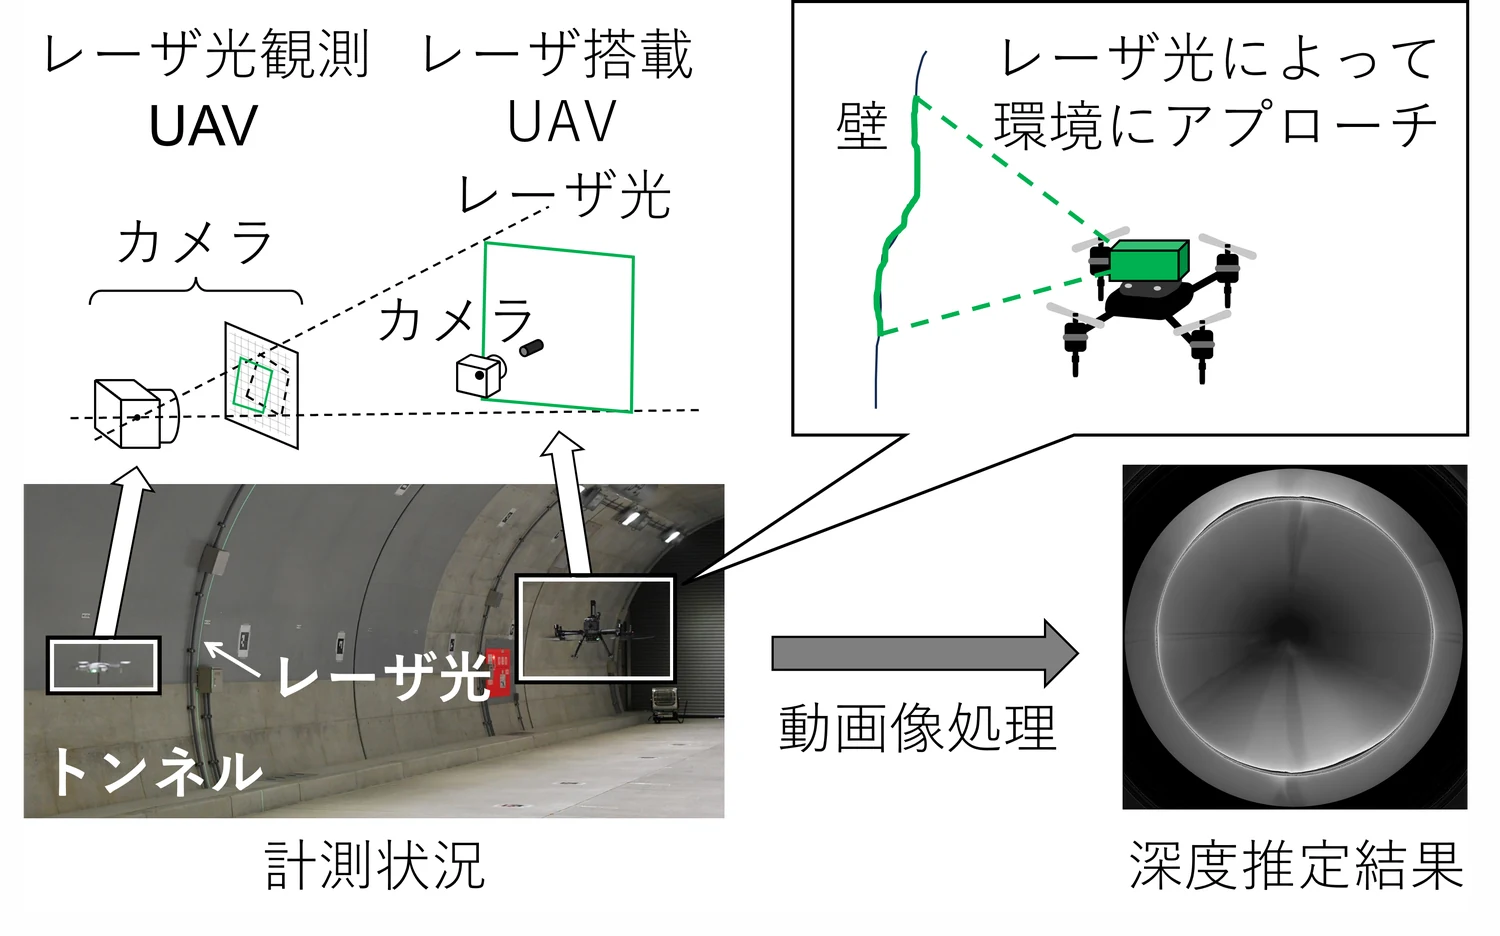
Vision-based sensing for textureless structures: A three-dimensional (3D) tunnel measurement method, which estimates the camera pose changes based on laser projection patterns. To estimate the relative poses of the two cameras, we designed a 2D–3D registration algorithm for the omnidirectional laser light. Our system measured 3D shapes without environmental textures. Also, the proposed method produced fewer errors in straight sections with few distinctive shapes than the 3D point set registration algorithm.
テクスチャの乏しい構造物のための視覚センシング:レーザの投影パターンからカメラの位置姿勢の変化を推定する,トンネルの3次元計測手法です.2台のカメラの相対位置姿勢を推定するために,全周レーザ光の2D–3Dレジストレーションを設計しました.環境のテクスチャに頼らずに3次元形状を計測でき,特徴の少ない直線区間では,3次元点群のレジストレーションよりも誤差を抑えることができました.